What the result can tell you
Backdrivability describes reverse motion driven from the joint output. Breakaway torque, moving resistance and apparent inertia answer different questions. A single number cannot describe all three.
| Conclusion | Decision | Basis |
|---|---|---|
| Use model-specific evidence | Some cycloidal and strain wave gearheads can be backdriven. Do not infer a universal threshold from the architecture name. | [S1] [S3] [S4] |
| Separate static and dynamic resistance | A starting measurement does not describe sustained motion at another speed. | [S1] |
| Keep rotor inertia separate from total inertia | N²·J_m is the ideal rotor contribution, not a contact-safety score. | [S5] |
| Qualify the installed system | Electrical regeneration and load holding need their own evidence alongside the torque check. | [S3] [S6] |
Backdrivable gearbox architectures: reverse efficiency, inertia scaling, and selection
A backdrivable gearbox transmits output-driven motion to its input once applied torque overcomes resistance. For selection, distinguish starting torque, moving losses and reflected inertia. Neither the architecture name nor the ratio alone establishes transparency, shock capacity or contact safety.
Reverse efficiency: a moving-state quantity
Reverse efficiency is useful mechanical power delivered at the input divided by power supplied at the output during reverse motion. At rest, both powers are zero; this ratio cannot predict static breakaway. The checker therefore accepts measured torque separately from the physics model’s assumed efficiency.
SEW-EURODRIVE gives η′ = 2 − 1/η and the η ≤ 0.5 self-locking criterion for its helical-worm gear units. This is manufacturer guidance for that transmission family, not a conversion rule for planetary, cycloidal or strain wave drives. A nonpositive result indicates the model’s self-locking region, not measured negative delivered power. The same source explicitly excludes self-locking as the sole hoist safety function. [S8]
Breakaway and moving losses need separate measurements
Record motor cogging, bearings, mesh preload, seals and lubricant conditions when investigating resistance. The diagram is a test checklist, not an additive static-torque equation: individual contributions can depend on shaft position, load and temperature. A measured installed-joint value already includes its losses.
For moving-state sensitivity only, the estimator uses τ_motor,out ≈ N·τ_motor,drag / η_rev. If an efficiency assumption already includes transmission losses, adding the same mesh losses again would double count them. This model does not estimate total static breakaway. Request approved lubricant and seal options from the supplier; no universal cold-temperature multiplier, grease grade or seal replacement is established here.
Ratio sensitivity does not predict a collision outcome
With a fixed ideal ratio and the same rotor, J_ref = N²·J_m. At a prescribed output acceleration α_out, the rotor’s inertial torque contribution is τ_rotor,out = J_ref·α_out. This excludes link and payload inertia, elasticity, damping, friction and control response. [S5]
Illustrative arithmetic: J_m = 0.00011 kg·m² and α_out = 500 rad/s² give 3.52 N·m for N = 8, versus 550 N·m for N = 100. These are rotor contributions at an imposed acceleration, not predicted peak contact torques or tooth-failure thresholds. Rotor kinetic energy is stored energy; regeneration or dissipation additionally requires an electrical or mechanical energy path. [S6]
| Architecture | Established evidence / model | Unknown for your candidate | Selection action |
|---|---|---|---|
| Single-stage planetary / low ratio | For the same rotor, reducing N reduces N²·J_m; this is an ideal scaling result, not a family performance rating. | N/A — no matched planetary efficiency, breakaway or shock test is cited here. | Request complete-joint traces, rotor inertia, motor size and thermal duty. |
| Research cycloidal QDD | The 10:1 C-QDD prototype reports 1.99 N·m starting and 1.36 N·m moving resistance. [S1] | N/A — these results do not establish a range for other cycloidal units. | Match test conditions before comparing a supplier sample. |
| Two-stage planetary | Use the total speed ratio for ideal reflected rotor inertia; stage count alone does not establish friction. | N/A — matched reverse-efficiency, breakaway and transient limits are not available here. | Request load/speed/temperature curves and approved transient load ratings. |
| Strain wave / harmonic gearhead | CSG-GH / CSF-GH distinguishes input starting torque from output backdriving torque. [S3] | N/A — select exact size, ratio and assembly; no family-wide efficiency or shock factor is inferred. | Check the matching catalog row and installed motor, brake and seals. |
| RV industrial cycloidal | RV-6E: 10 N·m; RV-20E / RV-40E: 42 / 47 N·m starting torque, input released. [S4] | N/A — dynamic curves and complete motorized-joint losses are not supplied by that table. | Request a bidirectional installed-assembly test; do not apply prototype ranges. |
| Ball screw — linear alternative | Linear force and travel require a lead-based model; evaluate our dedicated backdrivable linear actuator reflected mass tool and selection guide. | N/A — no matched screw, preload or linear breakaway data is cited here. | Use supplier thrust/lead data and a separate linear test with a validated holding strategy. |
| Worm / helical-worm | Self-locking is conditional; SEW supplies a family-specific criterion and hoist limitation. [S8] | N/A — the name or ratio alone does not establish self-locking or safe load holding. | Confirm the exact configuration and an independent holding arrangement where required. |
Proprioceptive sensing: calibrate the residual error
Motor current estimates electromagnetic torque after calibrating K_t and the current convention. Inferring external contact also requires transmission losses, joint dynamics and gravity. No ratio-only accuracy percentage or bandwidth threshold follows; compare the estimate with a reference sensor over the required speed, load and temperature window. [S5]
When backdriving may help
- Manual teaching, haptics or wearable following: test passive resistance against the task requirement.
- Legged joints: compare complete-system inertia and compliance for the intended impact event.
- Current-based force estimation: validate calibrated residuals before choosing sensor architecture.
- Energy recovery: verify that the inverter and supply can accept the returned energy.
When additional measures are required
- Gravity loads or power loss: specify and test a suitable holding arrangement, including brake fault behavior.
- Hoists: self-locking alone is not the safety function. [S8]
- Human contact: assess the application; low measured drag does not establish safe collision forces.
- Long static poses: compare continuous holding power and thermal duty against a braked alternative.
Published backdrive evidence: known and unknown
These values describe different test articles and are not a ranked product comparison. A gearhead with its input released is not equivalent to a complete motorized joint. N/A means the cited public evidence does not establish that item.
| Test article | Starting / breakaway torque | Dynamic torque | Conditions and limits | Source |
|---|---|---|---|---|
| Zhu et al. C-QDD research actuator, 10:1 | 1.99 N·m | 1.36 N·m | Concentric servo / torque-sensor setup, §V-B2. Prototype result; no cross-model guarantee. | [S1] |
| Rawal wearable-joint prototype | 1.20 N·m | N/A — not in abstract | Thesis abstract reports minimum torque. Ratio, temperature and dynamic protocol not established by the abstract. | [S2] |
| Nabtesco RV-6E | 10 N·m | N/A — starting table only | Catalog E-series table; input released, Molywhite RE00 grease. Confirm model configuration and temperature for use. | [S4] |
| Nabtesco RV-20E / RV-40E | 42 / 47 N·m | N/A — starting table only | Same catalog definition. Different sizes; values are not a ratio-only relationship. | [S4] |
| Harmonic Drive CSG-GH / CSF-GH | N/A — select exact size and ratio | N/A — no matched dynamic test here | Performance table distinguishes input starting and output backdriving torque; backdrive table values are maxima at stated conditions. | [S3] |
No proprietary product, patient or customer-deployment data is used. The worked examples below are calculations with stated assumptions, not field performance claims.
Estimator equations, units and boundaries
For an ideal rigid reduction, motor angular velocity is N times output velocity. Equating rotor kinetic energy on each side gives J_ref = N²·J_m. [S5]This leaves out the links, payload and other transmission elements.
| Output | Equation | What must be true / what is omitted |
|---|---|---|
| Reflected rotor inertia (kg·m²) | J_ref = N²·J_m × 0.0001 | J_m entered in kg·cm²; ideal fixed ratio. Excludes other inertia. |
| Motor-drag contribution (N·m) | τ_motor,out ≈ N·τ_f / η_rev | Constant reverse efficiency assumed for moving transmission. Not a prediction of total static breakaway. |
| Equivalent force (N) | F = τ_motor,out / L | L is the perpendicular moment arm. Not peak collision force. |
| Back-EMF (V, line-to-line peak) | V_LL,peak = K_e·N·|ω_out| | K_e already uses line-to-line peak per mechanical rad/s. No implicit RMS or phase conversion. |
| Rotor kinetic energy (J) | E_rotor = ½·J_ref·ω_out² | Rotor contribution only. Not total regenerated energy or contact energy. |
At rest, efficiency as a power ratio does not define static friction. The motor-drag approximation omits gearbox and seal losses and any load-dependent friction. Use the lab torque check for measured breakaway; use the estimator for sensitivity analysis. Tiny displayed values retain significant digits rather than being rounded to zero.
Compare architectures by the missing evidence
| Architecture | Potential reason to consider | Tradeoff to investigate | Evidence to request |
|---|---|---|---|
| Direct drive | Removes reduction losses | Motor size, heat and rotor inertia for required torque | Cogging / bearing drag and thermal envelope |
| Low-ratio geared drive | Reduces ideal reflected inertia for a fixed rotor | Larger motor demand; actual friction and backlash still matter | Complete-joint torque-speed and current-to-torque calibration |
| Strain wave gearhead | Compact reduction and positioning applications | Starting drag, elastic response and fatigue under the actual duty | Exact size / ratio table, lubrication and transient load limits |
| Cycloidal reducer | Candidate where packaging and load capacity suit the task | Large variation between prototypes and industrial assemblies | Bidirectional backdrive traces and installed configuration |
| Series elastic actuator | Physical compliance and spring-based torque estimation | Travel, damping, bandwidth, end stops and packaging | Spring curve, energy capacity and response with payload |
These questions are a selection framework, not manufacturer specifications. Reflected-inertia and feedback principles: [S5].
Are harmonic drives backdrivable?
The CSG-GH / CSF-GH catalog defines backdriving torque at the output where input rotation begins. It separately defines starting torque at the input; mixing the columns can produce a large selection error. [S3]
Check the exact assembly, ratio, lubricant and temperature before using a value. The catalog warns against relying on those torque figures to hold an external load and calls for a brake where backdriving is impermissible. This does not establish a universal requirement that every humanoid joint must use the same brake arrangement. [S3]
Are cycloidal drives backdrivable?
Yes, some designs are. The published prototype and industrial catalog evidence above demonstrate reverse motion at very different torque thresholds. Neither supports declaring an entire ratio range self-locking, assigning an automatic shock rating or claiming that manual movement will damage the reducer. [S1] [S4]
For a shortlist, first match required output torque, speed and envelope; then compare measured resistance for the installed motor and transmission. Treat missing dynamic curves as a supplier-data gap rather than inventing an efficiency or transparency score.
Electrical state and regeneration change the result
External motion can drive a motor as a generator. Returned energy may raise DC-link voltage; storage headroom and a correctly sized shunt can manage it. [S6]Nominal bus voltage is neither a protection threshold nor a measure of available energy absorption.
| State / option | What remains unknown | Next action |
|---|---|---|
| Open motor terminals | Mechanical drag plus motor effects, but not connected-inverter behavior | Record configuration; compare against the actual intended state. |
| Shorted phases or attached inverter | Speed-dependent braking and topology-dependent current paths | Use the manufacturer-approved test procedure and capture current / bus voltage. |
| Capacitor storage | Usable energy headroom and voltage ratings | Estimate ½·C·(V_max² − V_start²) and include all axes and losses. |
| Brake resistor / chopper | Pulse energy, peak and average power, thermal duty | Size and test the sink; verify fault behavior. |
| Battery or regenerative supply | Permitted charge current, state-of-charge and protection response | Confirm energy absorption across operating and fault states. |
The calculator uses a declared K_e convention to estimate open-circuit back-EMF. It does not solve winding current, inverter switching or capacitor charging. An unpowered gate command alone need not isolate every passive conduction path.
Contact safety requires a system assessment
ISO/TS 15066:2016 addresses collaborative industrial robot systems and their environment. Its official scope does not directly cover non-industrial robots, although principles may inform other applications. The official page lists it as published and to be revised when checked on 8 November 2026. [S7]
This guide does not reproduce body-region force limits from a public abstract or issue an ISO pass/fail result. Obtain the applicable complete requirements for the application and assess force, pressure, trapping, body region, pose, payload and protective measures. A within-limit breakaway measurement cannot substitute for that work.
Rotor inertia influences dynamics, but it does not alone determine peak contact force. No universal millisecond cutoff, gear-ratio safety boundary or unmeasured force-time curve is asserted here. Test the relevant contact and fault cases with the complete system.
Force transparency and sensor choices
Motor current relates to motor torque through the calibrated torque constant. Transmission friction and dynamics complicate inference at the output; an output sensor or elastic element offers another measurement path. [S5]
| Approach | What it observes | Limit / cost to qualify |
|---|---|---|
| Motor-current estimate | Motor electromagnetic torque | Needs calibrated losses and dynamics; validate residual error across load, speed and temperature. |
| Output torque sensor | Torque at its installation point | Added sensor, electronics and calibration; passive drag remains. |
| Series elasticity | Torque inferred from spring deflection | Needs spring calibration, travel and bandwidth validation. |
| Contact force sensor | Wrench at the sensor location | Mounting, cross-axis calibration and contact location constrain interpretation. |
No fixed bandwidth or cost ranking is assumed. Select the sensing arrangement from the required force resolution, available space and measured uncertainty.
A practical measurement plan
This is a suggested engineering plan, not a published acceptance standard. Select speeds, loads and temperature limits from the equipment specification and task.
- Define the configuration. Record part number, ratio, motor, seals, brake release, lubricant, electrical connection, run-in history and temperature. Support gravity-loaded links and guard the rig.
- Measure starting torque. Zero and calibrate the aligned sensor. Ramp output torque slowly from rest and record the peak at the first input motion. Account for fixture friction and gravity.
- Measure moving resistance. Record torque versus output speed in both directions over the required range. Capture ripple and test open-circuit and intended connected states separately.
- Repeat and report uncertainty. Include repeats, dwell history, application temperature extremes and load conditions. Record range and instrument uncertainty; compare the worst relevant result with the task limit.
If the measured range or uncertainty overlaps the limit, treat the selection as unresolved. Do not turn a small positive calculator difference into an unqualified acceptance.
Download the blank measurement worksheet (CSV)Risks, costs and minimum recovery paths
| Risk / symptom | Decision consequence | Minimum next step / alternative |
|---|---|---|
| Cold or changed grease increases resistance | Warm testing can understate application drag | Repeat across the thermal window. Discuss approved lubrication with the supplier. |
| Resistance changes with inverter connected | Electrical braking is mistaken for gearbox friction | Compare recorded states under approved isolation procedures; investigate the inverter path. |
| High clockwise / counterclockwise difference | Alignment or load effects distort the result | Check sensor zero, gravity, fixtures and alignment before modifying the reducer. |
| Low ratio increases motor demand | Package, inverter and thermal cost may grow | Compare full actuator duty and mass against a geared design with feedback or elasticity. |
| A sensor is treated as passive compliance | Powered behavior is confused with power-off behavior | Measure both states; consider physical compliance where the task requires it. |
| Friction is used to hold a gravity load | Uncommanded reverse motion may occur | Specify a validated holding strategy; use a suitable brake where required. |
| No usable measurements | Architecture cannot be accepted from a label | Use the supplier checklist; request matched traces or a sample test before selection. |
Worked engineering examples with explicit assumptions
These examples demonstrate arithmetic, dynamic scaling, and tradeoffs in joint actuator selection. They are not robot deployments or vendor performance claims.
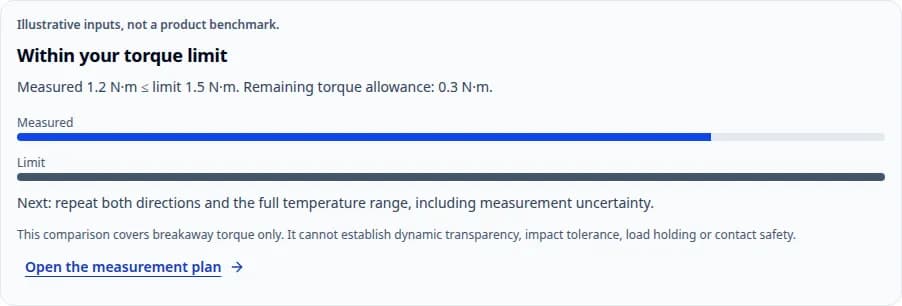
1. Torque check
Assume measured output breakaway 1.20 N·m and a task limit of 1.50 N·m.
1.50 − 1.20 = 0.30 N·m remaining allowance.
Next: compare repeated worst-case measurements and uncertainty. No impact or load-holding approval follows.
2. Ratio sensitivity
Assume the same 0.35 kg·cm² rotor and compare N = 10 with N = 100.
J_ref = 0.0035 versus 0.35 kg·m²: 100× difference.
Next: compare the actual candidate rotors and total link inertia. Holding J_m constant is a comparison assumption.
3. Voltage convention
Assume K_e = 0.065 V·s/rad line-to-line peak, N = 10 and output speed 8 rad/s.
Motor speed = 80 rad/s; back-EMF = 5.2 V peak.
Next: check regeneration energy and inverter limits even with a nominal 48 V bus. This is not an overvoltage simulation.
4. Prescribed acceleration comparison
Assume the same J_m = 0.00011 kg·m² rotor, output acceleration 500 rad/s², and ideal rigid ratios N = 8 and N = 100.
J_ref = 0.00704 versus 1.10 kg·m²; rotor inertial torque = 3.52 versus 550 N·m. Acceleration is an input, not inferred from an impact force.
Next: include links, payload, compliance and actual rotor choices, then compare measured transients with the exact reducer rating. No failure threshold is supplied.
5. From torque uncertainty to task force
Assume a calibrated quasistatic external-torque estimate has ±0.70 N·m residual uncertainty and a 0.35 m perpendicular moment arm.
Equivalent tangential force uncertainty = 0.70 / 0.35 = ±2 N. This excludes uncertainty in contact location and other force components.
Next: compare this uncertainty with your task resolution and reference measurements. It establishes no contact-force safety limit, detection delay or stopping force.
Backdrivability FAQ
Meaning and selection
What is a backdrivable gearbox and what determines backdrivability?
A backdrivable gearbox permits output-applied torque to drive its input once resistance is overcome. Starting torque, moving losses and reflected inertia are separate selection quantities. Low ratio alone does not establish low resistance or safe contact.
Are cycloidal drives backdrivable?
Some are. The C-QDD research joint and Nabtesco catalog both document backdriving, under different conditions. Choose by model-specific measurements, not the cycloidal label. [S1]
Are harmonic drives backdrivable?
The manufacturer publishes output backdriving torque for specific gearheads. That is a starting threshold, not a guarantee of low resistance across operating conditions. [S3]
Which gearbox types offer the highest backdrivability for robotics?
There is no universal architecture ranking. For the same rotor, a lower ratio reduces ideal reflected rotor inertia, but actual breakaway and moving resistance need matched tests. The evidence matrix separates prototype results, catalog data and unknown candidate specifications.
Does high forward efficiency guarantee a backdrivable gearbox?
No. Forward efficiency is a moving power ratio, not a static breakaway test. SEW gives η′ = 2 − 1/η for its helical-worm gear units; do not generalize it to all reducers. Request output breakaway and reverse torque-speed data for the exact assembly. [S8]
Using the tool
Where do I get my allowable torque limit?
Define it from the task, force direction and perpendicular moment arm, then account for uncertainty. A quasistatic relation τ = F·L helps convert a task force requirement; it is not a collision safety limit.
Can I enter a zero limit?
Yes. Zero is accepted for torque fields. A zero limit leaves no allowance for measured resistance; instrument resolution still matters. Other physics fields show their own accepted ranges.
Why is there no transparency score?
A universal score would combine quantities without a validated acceptance method. The tool instead reports measurable torque comparison and explicit model quantities.
What units does the estimator use?
Rotor inertia is entered in kg·cm² and converted to kg·m². Speed is mechanical rad/s; K_e must be line-to-line peak volts per mechanical rad/s. Convert RMS, phase or rpm-based constants before entering them.
Why does the estimated torque differ from my bench test?
The estimator includes only an assumed motor-drag contribution and constant reverse efficiency. It omits gearbox, seal and load-dependent losses and cannot predict total static breakaway.
Measurement and controls
What is static versus dynamic backdrive torque in a gearbox?
Static breakaway torque is the peak torque needed to initiate reverse motion from rest. Dynamic backdrive resistance is measured during continuous rotation at a stated speed. They are distinct metrics; neither substitutes for the other.
Should the motor be open-circuit or connected?
Record the intended operating state and test it. Open terminals, shorted phases and an attached inverter can produce different resistance. Change wiring only using the equipment manufacturer’s isolation procedure.
How should I handle temperature and run-in?
Record grease, temperature and run-in history, then repeat at application extremes within manufacturer limits. No universal warm-up duration or cold-temperature multiplier is assumed.
Can motor current measure external contact force through a gearbox?
Current supports a motor-torque estimate. Estimating external force through a gearbox also requires calibrated transmission friction, reflected inertia, gravity, and load-side validation. [S5]
Will adding a torque sensor reduce passive friction?
No. It can support feedback control when powered, but does not remove mechanical friction or reflected rotor inertia. Compare the passive and powered responses separately.
Risk and next steps
Is a within-limit result an ISO safety approval?
No. It compares two torque values only. Contact assessment requires the complete application, including contact pressure, trapping, pose, payload and protective measures. [S7]
Can backdriving friction hold a gravity-loaded joint?
Do not use a catalog backdriving value as a load-holding margin. Where reverse motion is prohibited, the manufacturer calls for a brake; validate the full holding arrangement. [S3]
Does back-EMF below the bus mean regeneration is safe?
No. Controlled regeneration can still charge the DC link. Check the supply’s ability to absorb energy, capacitance, protection thresholds and braking duty cycle. [S6]
Does a series elastic element solve every impact problem?
No. Spring travel, energy capacity, damping and end stops must suit the event. Compliance adds packaging and control tradeoffs and still needs testing.
What should I request when sourcing a backdrivable gearbox or joint?
Request the exact configuration part number, bidirectional breakaway torque traces, speed-dependent reverse friction curves, grease operating temperature window, holding brake strategy, and regeneration limits. Use the RFQ checklist on this page.
Sources and evidence limits
Prepared and maintained by Humanoid Joint, a commercial joint-actuator supplier. We may supply components discussed in this guide; cited third-party results are not our product tests or endorsements.
First recorded in this site’s repository: . Public publication date is unverified. Next evidence review due , or sooner if a source, model or test procedure changes.
Reviewed 8 November 2026. Research, thesis, catalog and teaching material have different scopes; the locator below identifies what was checked. Catalog revision dates and unknown test conditions are not invented. Confirm current documentation before procurement.
- [S1] Zhu et al., Cycloidal Quasi-Direct Drive Actuator Designs (2025)
Version 2, 20 March 2025, §V-B2. Prototype results; not a commercial product specification.
- [S2] Rawal, Cycloidal-drive joint design for wearable exoskeletons (2020)
NJIT thesis record, abstract. Supports 1.20 N·m minimum backdrive torque; no dynamic torque value is supplied in the abstract.
- [S3] Harmonic Drive, CSG-GH / CSF-GH catalog
PDF page 3, Table 068-1: CSG-GH performance table, notes 3–5 and load-holding warning. No load, 25°C surface temperature. Catalog footer: Rev 02-15; confirm the current revision for procurement.
- [S4] Nabtesco, Precision Reduction Gear RV catalog
PDF page 45, printed page 91: Product Selection → Backdriving torque, E-series table. Input released; Molywhite RE00 grease. Linked from the manufacturer’s downloads library; confirm current revision for procurement.
- [S5] MIT, Robotic Manipulation — robot hardware notes
“An aside: link dynamics with a transmission” and “Torque-controlled robots.” Ideal inertia transformation and limits of current-based torque control.
- [S6] Elmo Motion Control, Regenerative energy — theory
Regenerative energy and bus capacitance sections. Energy storage and shunt-resistor sizing; not a universal inverter fault-state model.
- [S7] ISO/TS 15066:2016 — Collaborative robots
Official scope and publication status checked 8 November 2026. Industrial robot systems; public abstract is not the full normative text.
- [S8] SEW-EURODRIVE, Self-locking — helical-worm gear units
Edition 02/2025, Self-locking section and Information box; checked 8 November 2026. Family-specific reverse-efficiency guidance; explicitly excludes self-locking as the sole safety function for hoists.
Turn the result into a supplier test request
Send a configuration and test envelope, not just “high backdrivability.”
- Joint task, payload, required torque and speed, perpendicular moment arm and envelope.
- Allowable output resistance and how the limit was derived, including uncertainty.
- Exact reducer / motor / seal / brake assembly, lubricant, direction and temperature range.
- Starting and moving torque traces, electrical states, regeneration limits and holding strategy.