Resources
This library is built for procurement and engineering alignment, not general marketing reading. Each article includes decision criteria, risk controls, and practical actions you can reuse in real RFQ and validation workflows.
Read articles in decision order so your team moves from model screening to RFQ quality and then to customization governance without missing critical handoff details.
| Project Stage | Recommended Article | Decision Output |
|---|---|---|
| engineering | Crossed Roller Bearings vs. Thin-Section Angular Contact Bearings in Humanoid Robot Joints: A 2026 Procurement and Rigidity Guide | Reusable acceptance criteria and checklists for supplier communication. |
| engineering | EtherCAT vs. CAN FD vs. Single-Pair Ethernet (100BASE-T1) in Humanoid Robot Joint Actuators: A 2026 Sourcing, Harness Mass, Latency, and EMC Guide | Reusable acceptance criteria and checklists for supplier communication. |
| product | Joint Torque Sensors vs. Proprioceptive Current Sensing in Humanoid Actuators: A 2026 Engineering and Procurement Guide | Reusable acceptance criteria and checklists for supplier communication. |
You can also filter by buyer intent in our product, company, and news categories.
Choose a reading track based on the decision your team needs to make this week. This keeps article consumption tied to real program milestones instead of passive browsing.
| Track | Primary Question | Expected Team Output |
|---|---|---|
| Architecture Fit | Are torque-speed and interface assumptions frozen enough for quote comparison? | Shortlist with comparable RFQ inputs. |
| Factory Qualification | Can the supplier hold CTQ stability from pilot to MP? | Audit findings with closure owners and due dates. |
| Delivery & Compliance | Are trade-term ownership and declarations ready for release? | Shipment-ready gate checklist before dispatch. |
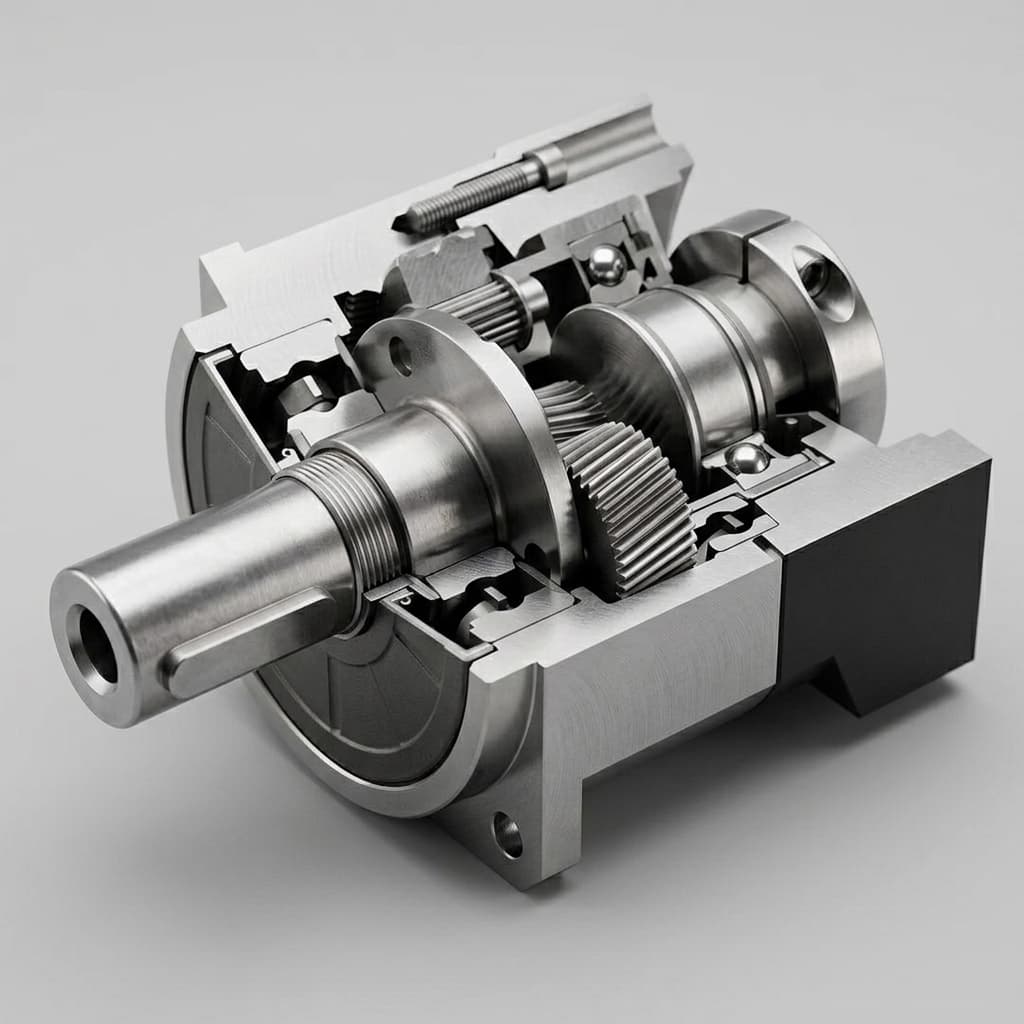
Compare crossed roller and angular contact bearings for humanoid joints: stiffness, friction, and sourcing limits. Use the RFQ checklist to qualify your design.
Compare EtherCAT, CAN FD and 100BASE-T1 for humanoid joints: calculate latency and harness mass, check EMC limits, and prepare a supplier RFQ with evidence.
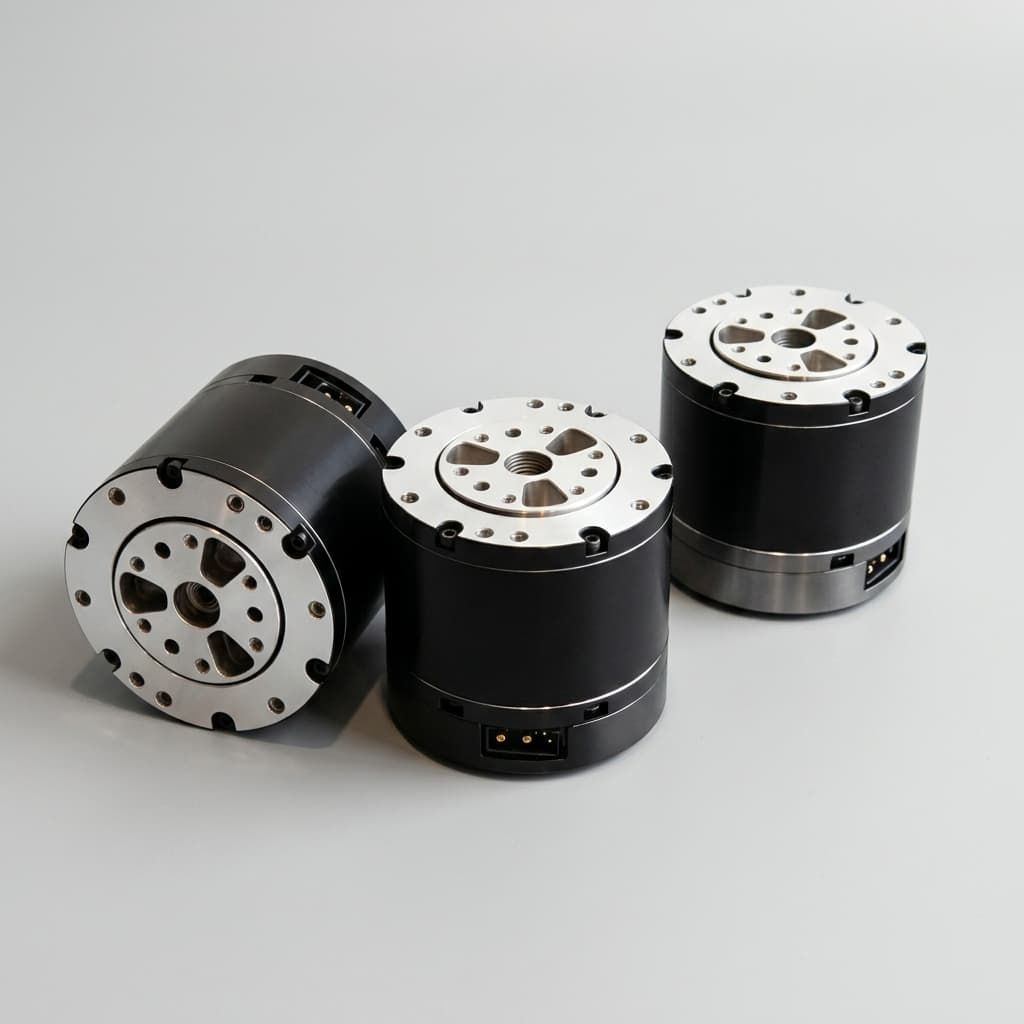
Compare joint torque sensors vs current sensing for humanoid actuators: friction, bandwidth, calibration and cost. Use the RFQ checklist to brief suppliers.
Compare GaN vs silicon MOSFETs for humanoid joint inverters. Review losses, thermal limits, DC-link sizing and supplier evidence before sending a joint RFQ.
Compare QDD vs high-gear-ratio humanoid actuators: inertia, thermal limits, sensing and supplier evidence. Use the RFQ checklist to request comparable quotes.
Compare rotary vs linear actuators for humanoid robot limbs: torque mapping, roller screw trade-offs, thermal limits and sourcing. Use the 2026 RFQ checklist.