Resources
Engineering design, validation, and sourcing guidance for humanoid robot joint architecture, cable routing, thermal limits, and actuator integration.
This archive page keeps topic-specific guides grouped for quick review during procurement planning and engineering evaluation cycles.
Return to the full blog index if you need cross-category reading order for your team.
For this category, prioritize decision evidence over generic claims:
Compare ASC vs mechanical brakes for humanoid joints in 2026 sourcing. See SGF, BOM, weight, ISO 13482 limits, and RFQ checks before contacting engineering.
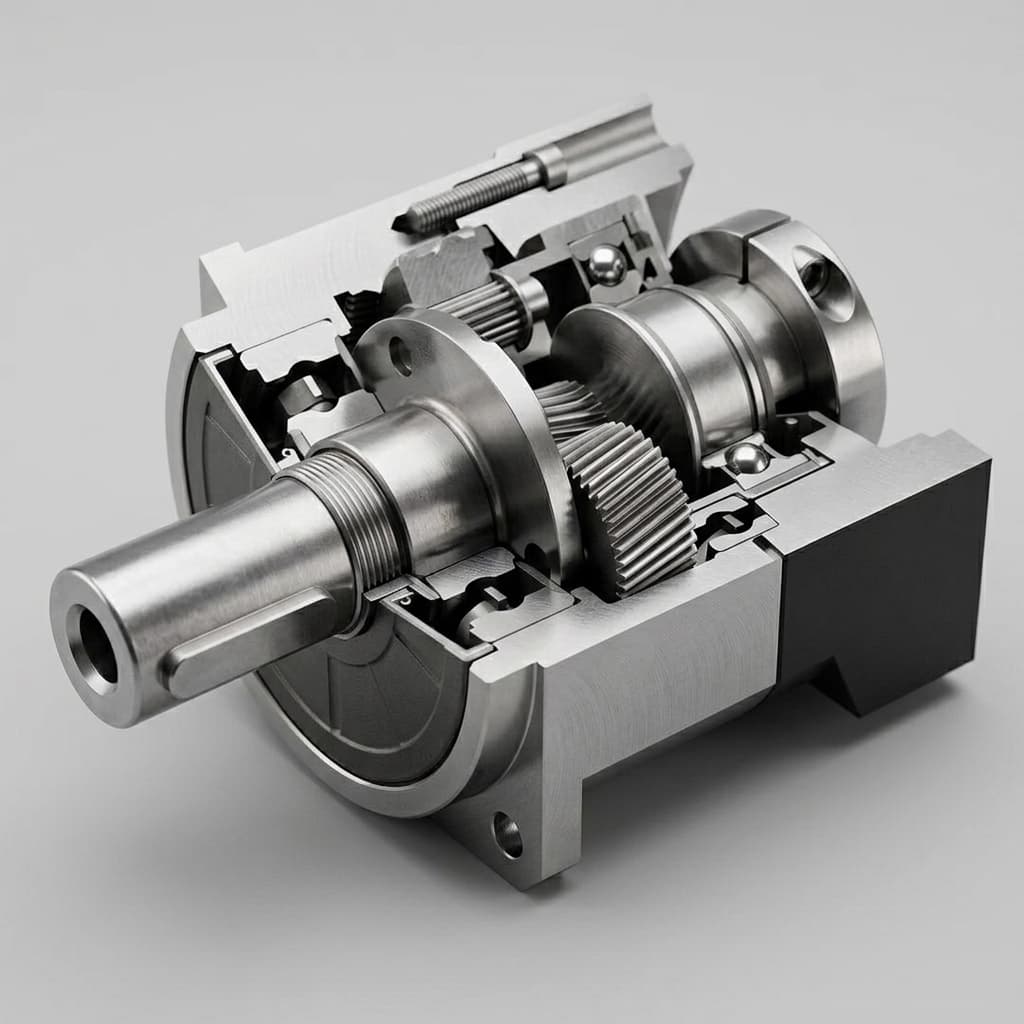
Compare admittance control vs. impedance control for humanoid joints: sensors, latency, actuator trade-offs, and RFQ checks. Contact Humanoid Joint today.
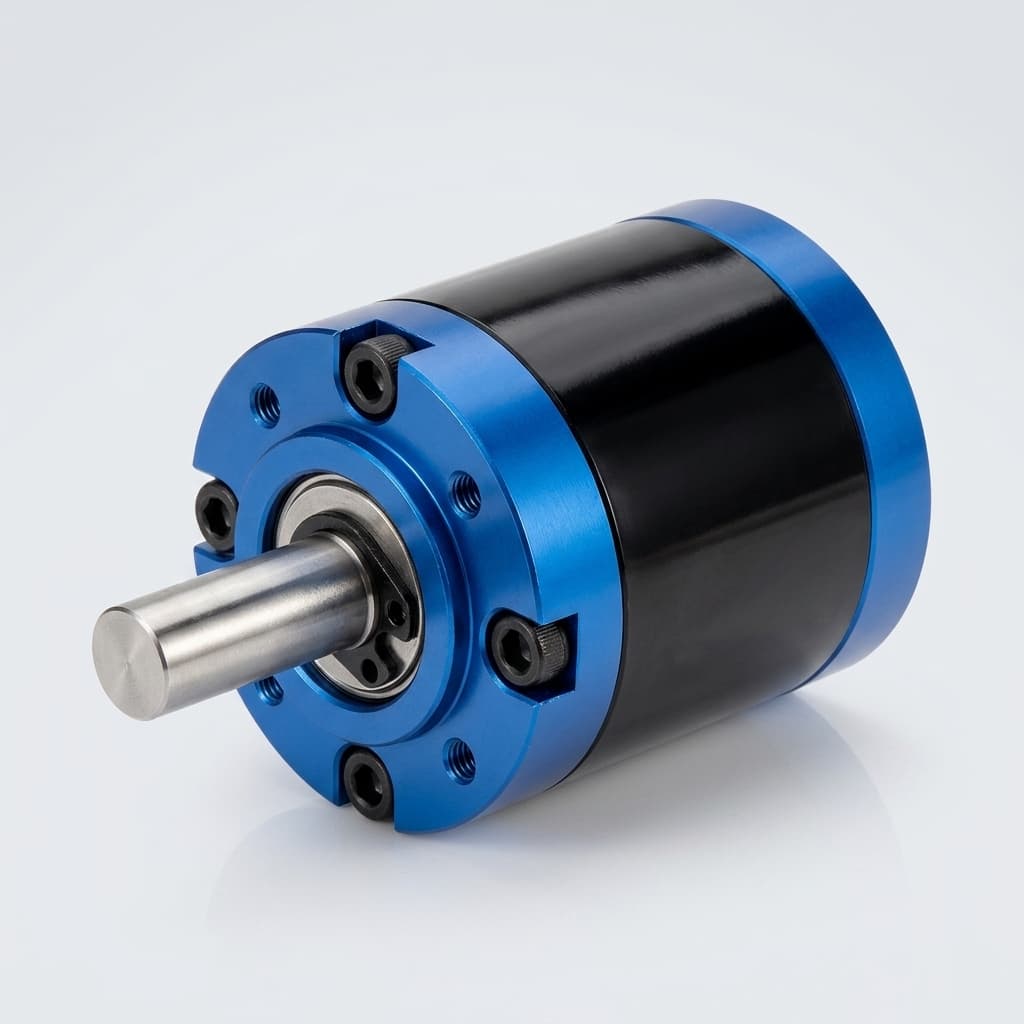
Compare admittance versus impedance control for robotic joints with selector logic, hardware limits, validation tests, and RFQ checks. Request a design review.
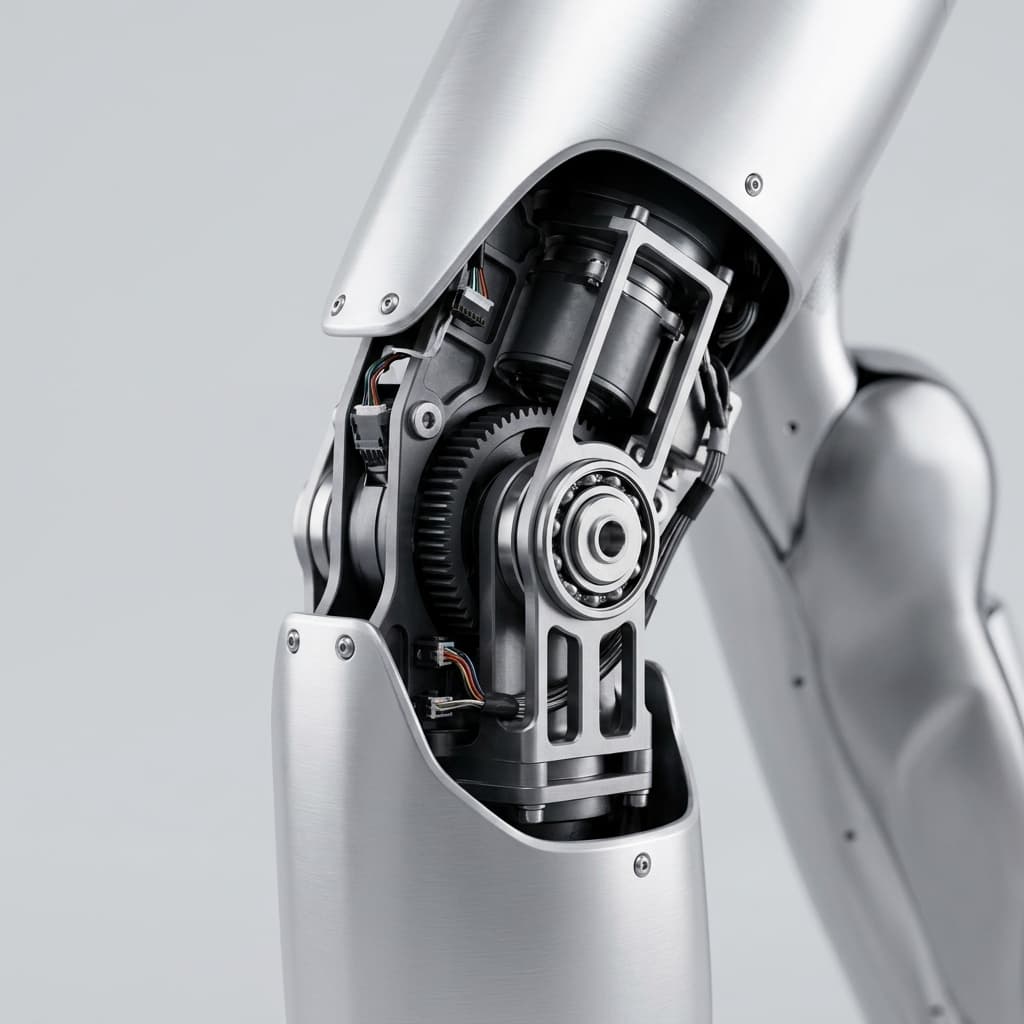
2026 procurement guide for dual-encoder humanoid joints: compare motor-side and output-side feedback, impact resilience, safety risks, and RFQ checks.
Procurement guide for hollow-shaft humanoid joints. Compare BOM costs, bearing tradeoffs, and cable routing strategies for 2026 robot architectures.
A comprehensive 2026 cost and scalability analysis comparing in-house joint assembly against sourcing pre-integrated actuator modules for humanoid robots.