Resources
Application engineering, customization strategy, and integration guidance for humanoid joint actuators, drive modules, and assemblies.
This archive page keeps topic-specific guides grouped for quick review during procurement planning and engineering evaluation cycles.
Return to the full blog index if you need cross-category reading order for your team.
For this category, prioritize decision evidence over generic claims:
Compare ASC vs mechanical brakes for humanoid joints in 2026 sourcing. See SGF, BOM, weight, ISO 13482 limits, and RFQ checks before contacting engineering.
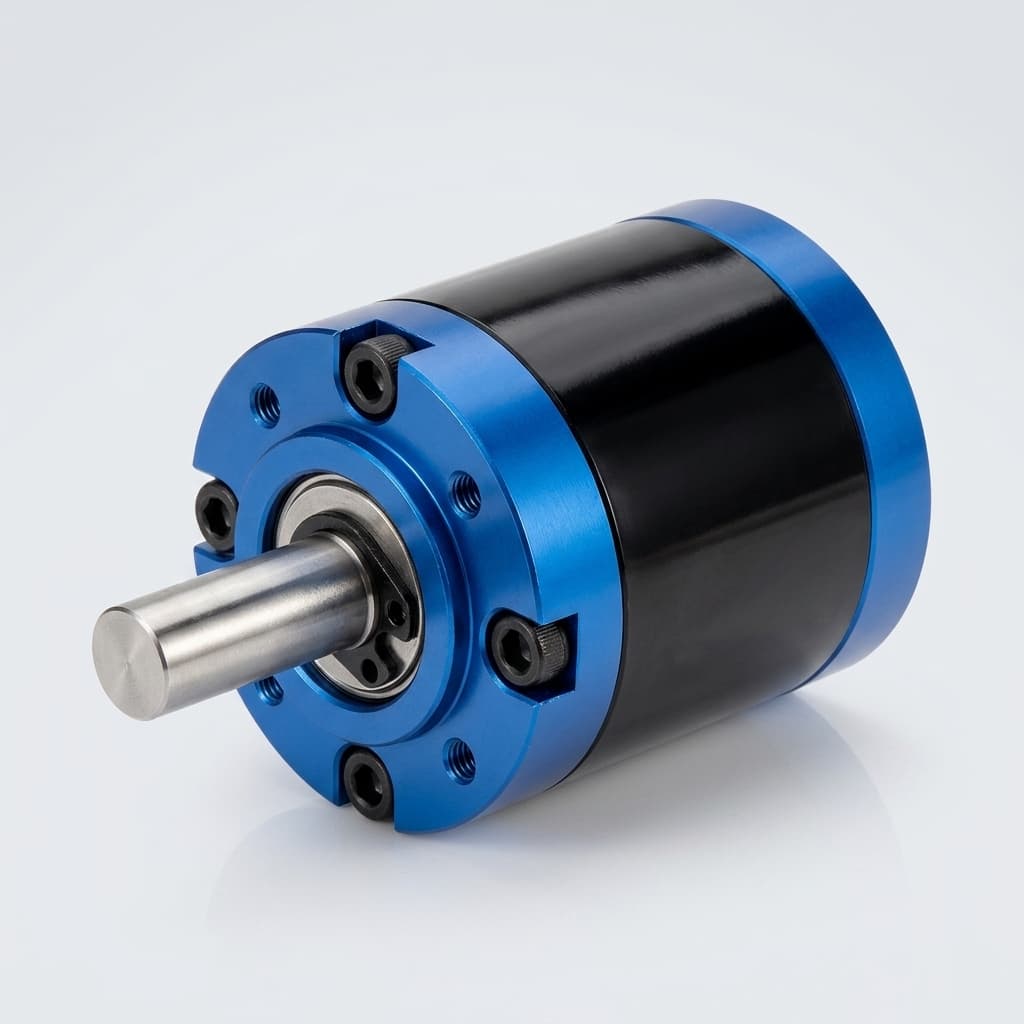
Compare admittance versus impedance control for robotic joints with selector logic, hardware limits, validation tests, and RFQ checks. Request a design review.
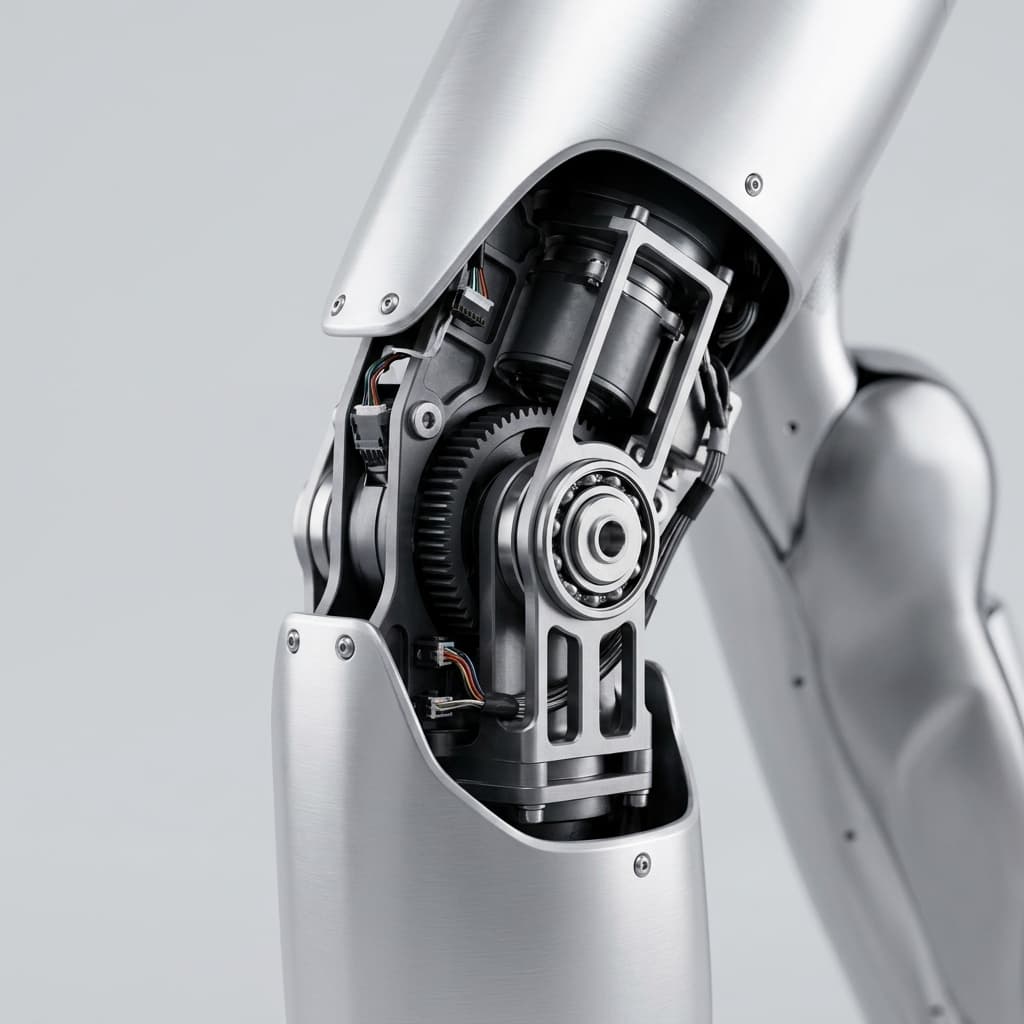
2026 procurement guide for dual-encoder humanoid joints: compare motor-side and output-side feedback, impact resilience, safety risks, and RFQ checks.
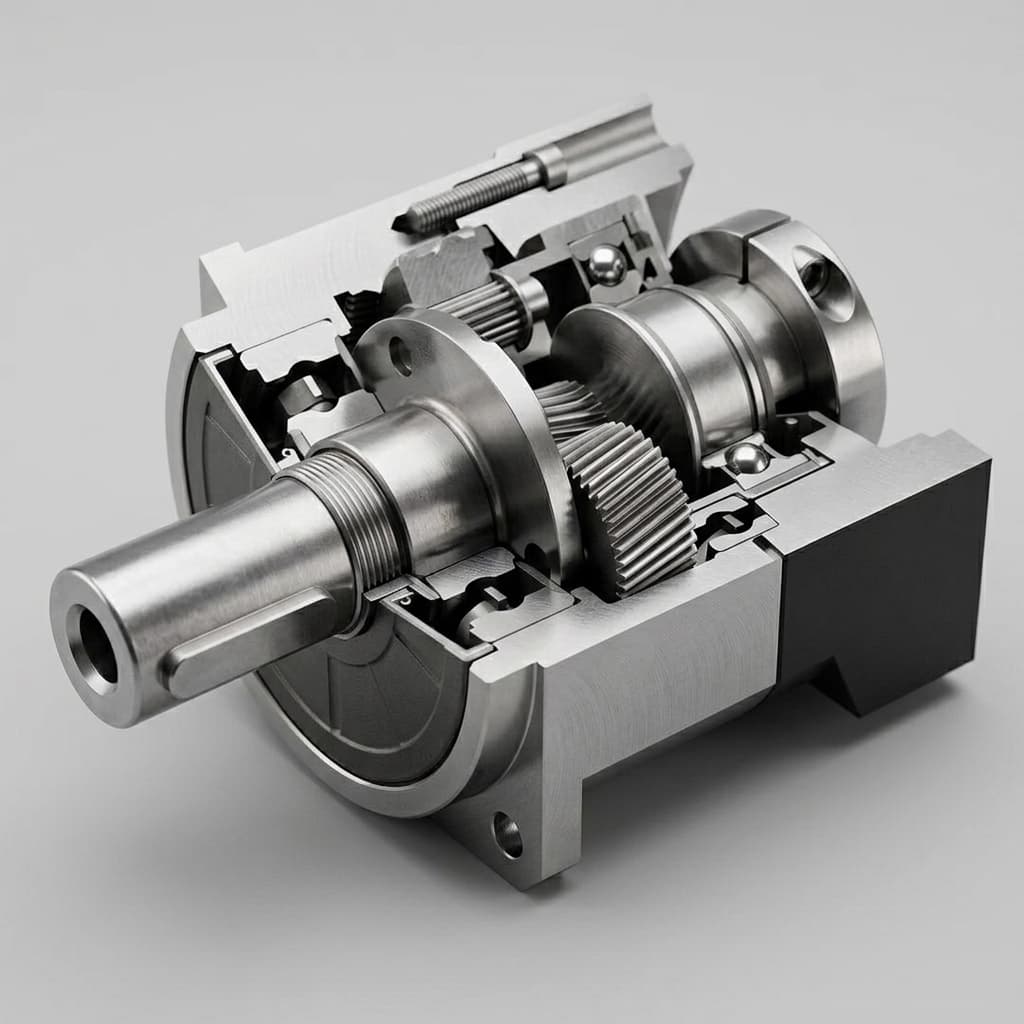
Procurement guide for hollow-shaft humanoid joints. Compare BOM costs, bearing tradeoffs, and cable routing strategies for 2026 robot architectures.
Compare harmonic and cycloidal drives for humanoid robot joints, fatigue risks, shock loads, and supplier checks before selecting durable actuator modules.
Use this 2026 guide to compare 48V and 400V humanoid joint architectures by safety, wiring weight, TCO, supplier risk, and RFQ readiness.